ACTUATORS FOR ROBOTIC HANDS

  • Human-Level Force
  • Industrial Durability
  • Series-Ready

OUR COMMITMENT

Provide long-term competitive advantage to our customers through innovative and reliable mechatronic solutions, from advanced research to series production.

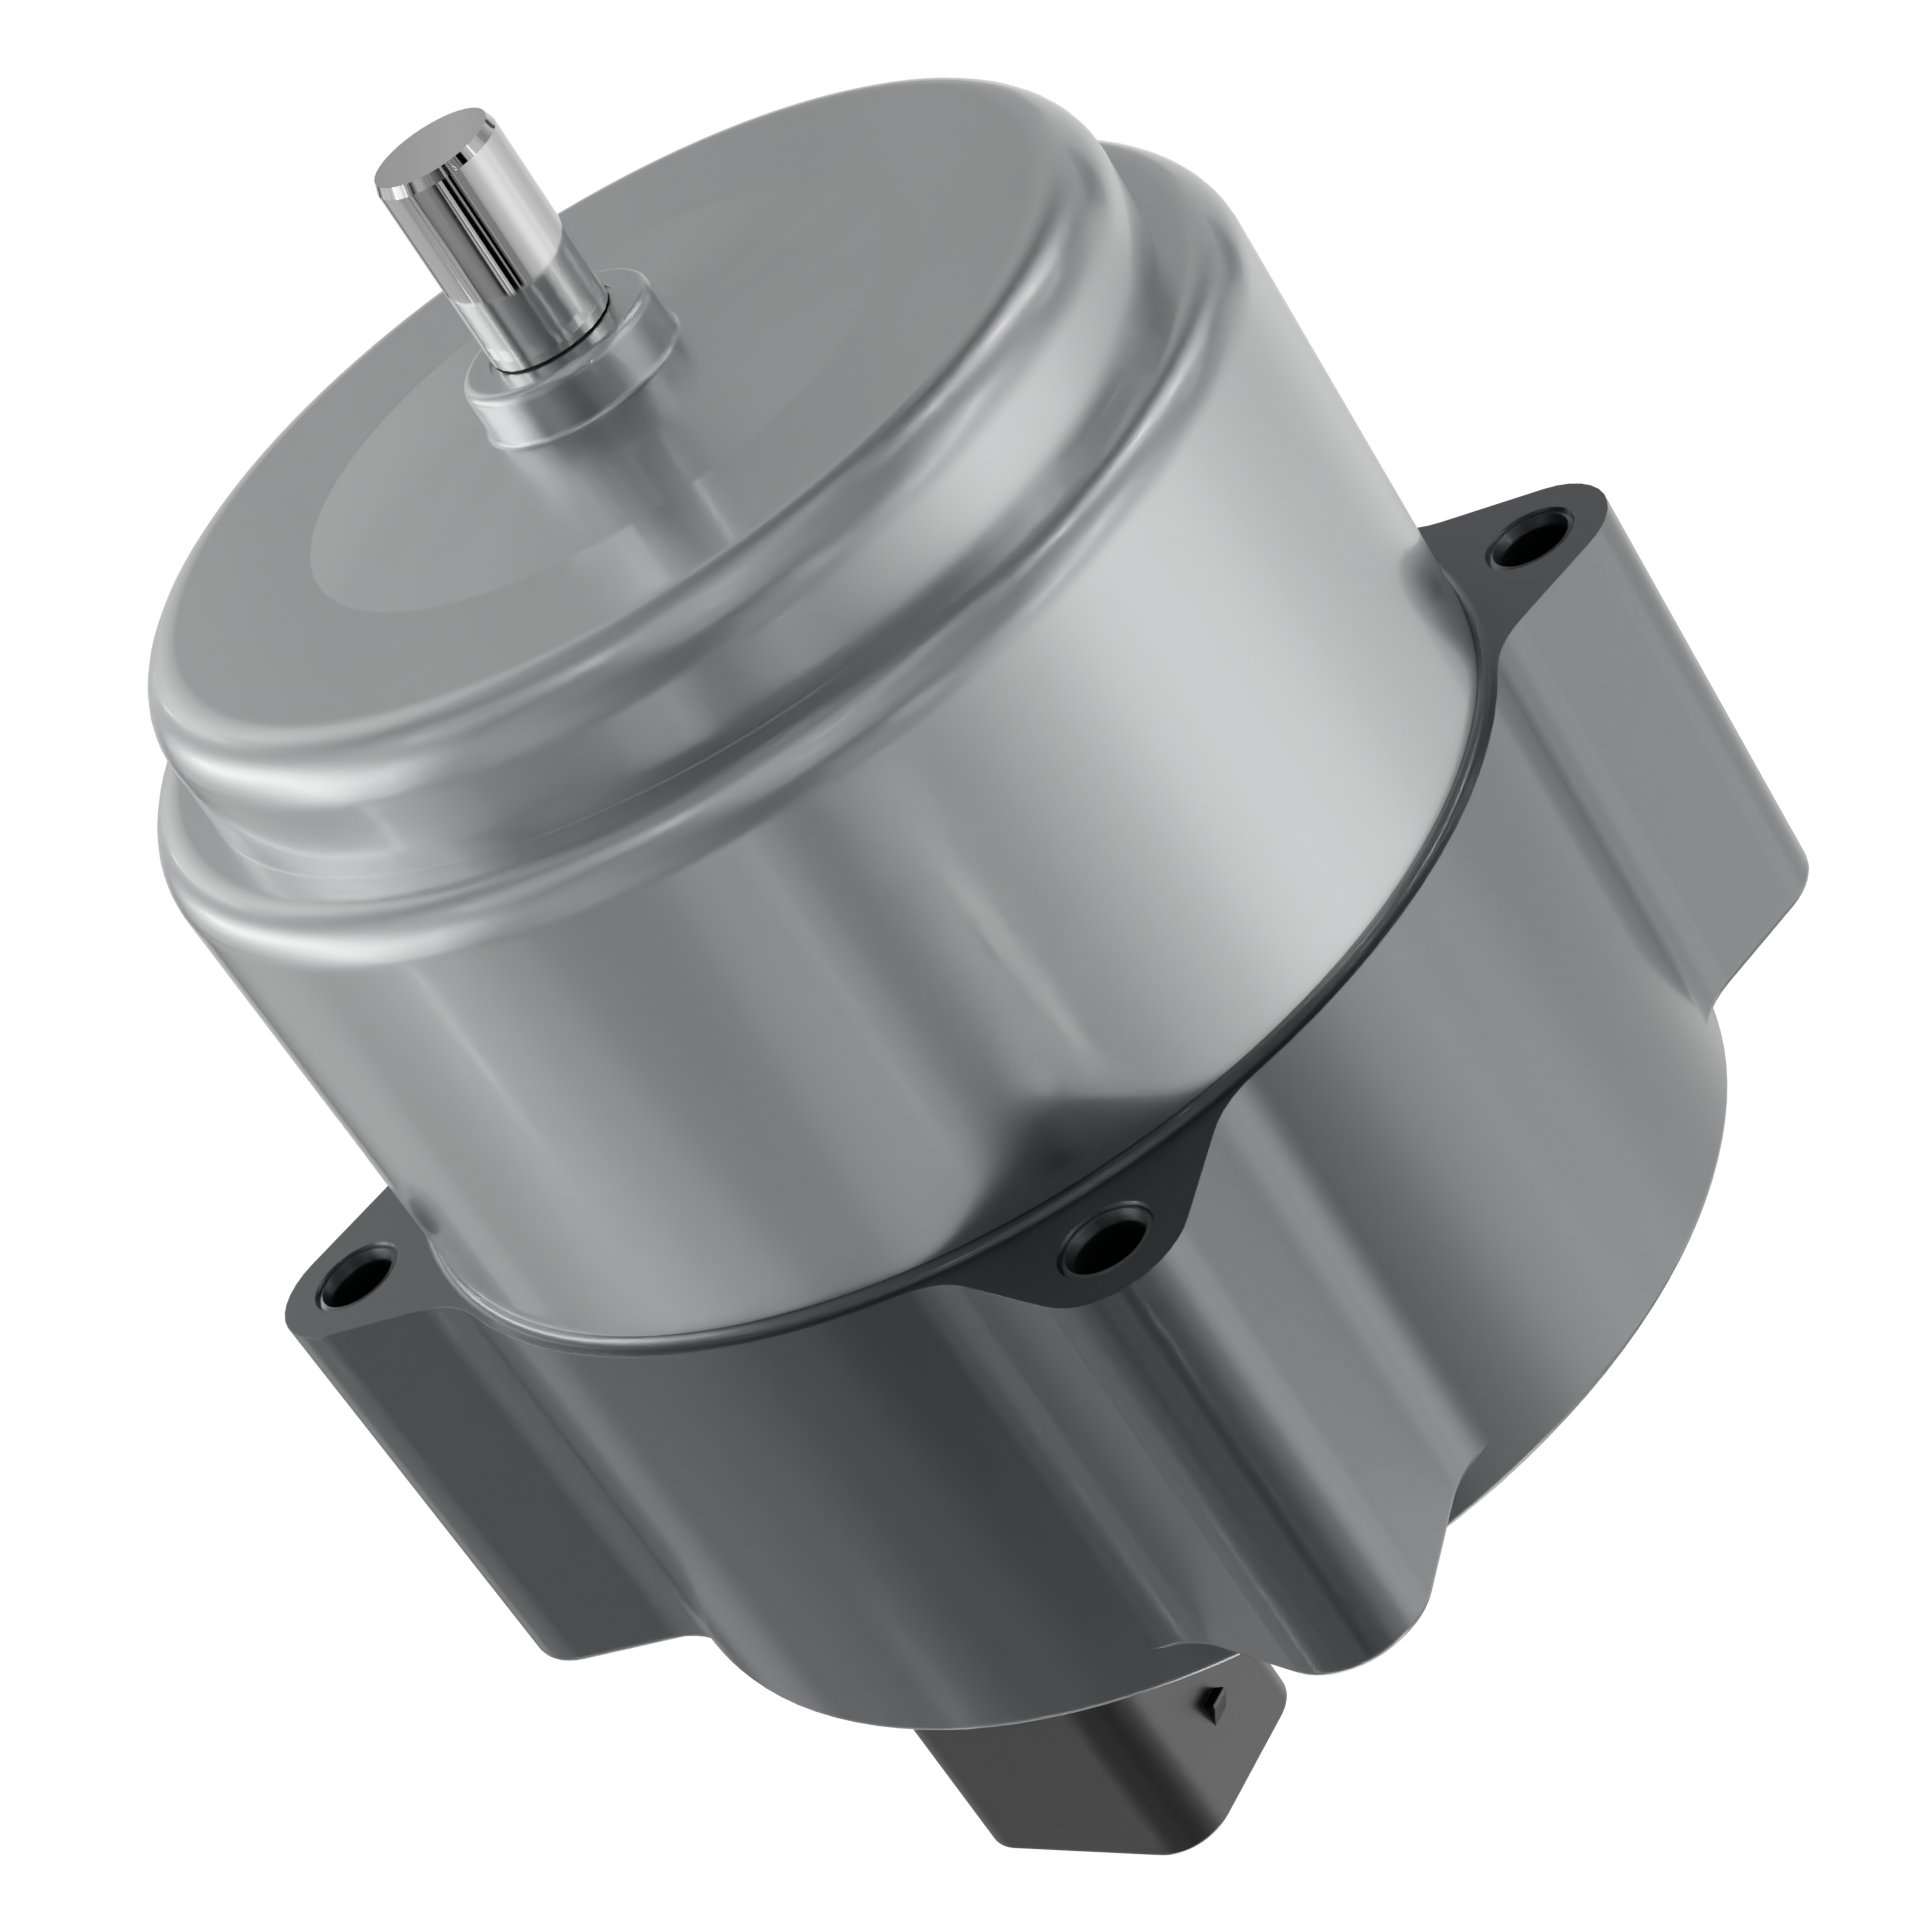
GEN 2 ROBOTICS ACTUATOR

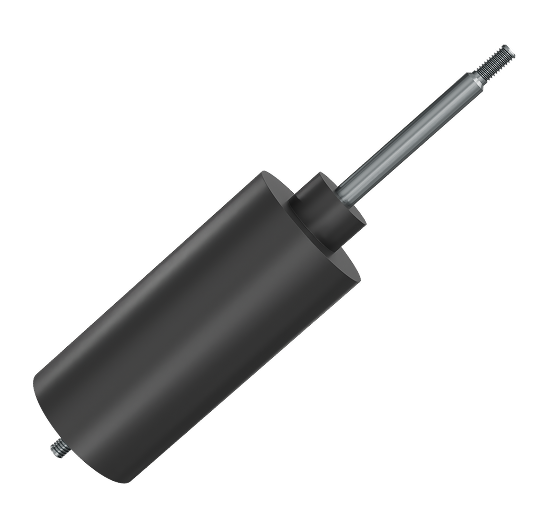
1.5 Nm Peak Under 50 g: Torque Without the Weight
Low Cogging, High Backdrivability: Natural Finger Motion
Low Heat at Peak Torque: Dexterity That Lasts
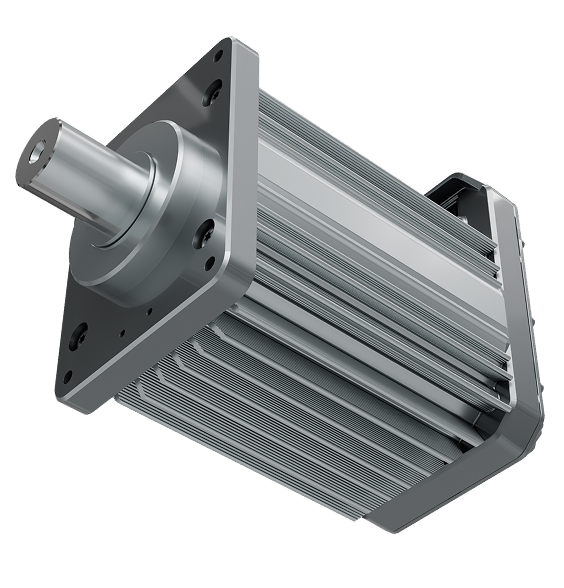
Inside a robotic finger, every gram and every degree counts. Our Gen 2 actuator delivers 1 to 1.5 Nm peak and 0.5 to 1 Nm continuous in under 50 g, in two sizes. Enough torque to drive a joint, without adding inertia at the end of the arm.
An actuator that fights back through its gearbox costs you dexterity first, then uptime. Low cogging and high backdrivability give the finger a natural, compliant motion, and heating stays low even at peak torque. Your hand moves like a hand, shift after shift.
The costly surprise usually comes later: a joint that works in the prototype, then needs a redesign for production. We designed this actuator for scalability, durability and manufacturing from day one, and its compact body adapts to different gearbox configurations. From prototype to fleet, same joint.

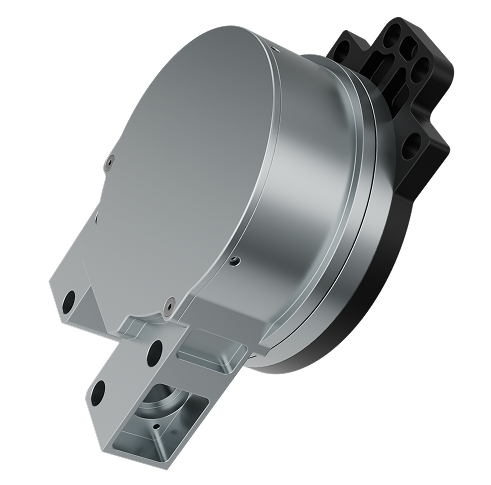
FINGER ACTUATION MODULE

One Module per Finger: Fewer Parts to Integrate
Air or Liquid Cooling: Thermal Control Built In
Tailored Design: Fits Your Hand and Forearm
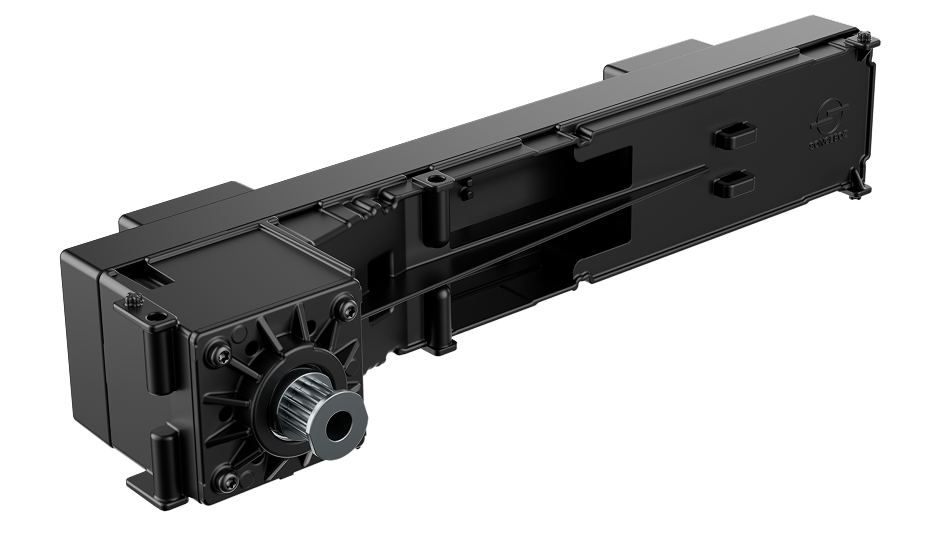
All degrees of freedom of one finger in a single compact unit: actuation, custom gearbox, thermal management and control electronics. One module per finger replaces a stack of separate parts, and the interfaces between them, that you would otherwise integrate and validate yourself.
Air or liquid cooling, integrated in the module and selected for your thermal budget and the space available in the hand or forearm. Heat, wiring and assembly are solved at module level, not discovered during system integration.
The module geometry is designed around your hand and forearm architecture, and built to meet the toughest durability requirements of robotic hand makers. Fewer parts to source, fewer interfaces to validate, one supplier accountable for the complete finger.

ROBOTIC HAND

40 N Fingertip Force: Human-Level Grip
20 DoF, 16 Actuated: Full Dexterity
Tactile Fingertips: Every Contact Sensed
20 degrees of freedom, 16 of them actuated, with full palm integration and backdrivable joints. Our actuators are tested in a complete dexterous hand, not as isolated joints on a bench.
40 N of fingertip force, at human level, with tactile sensors in the fingertips. Enough to test grip, hold and repetition under real loads, on industrial tasks a datasheet cannot cover.
Designed and made in Europe with MMT, our technology partner, the hand is the platform where we validate our robotics mechatronics against the most demanding industrial use cases, before they reach your line. You integrate actuators already proven in a complete hand.

TAILOR-MADE MECHATRONIC SOLUTIONS

full support that drives your success

innovation that moves industries forward

BUILT FOR YOUR PERFORMANCE

PROVEN LEGACY, TRUSTED PARTNER
Since 1936, we have stood as a pillar of precision mechatronics, driving innovation and setting benchmarks across industries. Our enduring legacy makes us a trusted partner in automotive, truck, industrial, and medtech markets. With proven reliability and forward-looking expertise, we deliver solutions that empower the future.
Learn more